I'm a third-year Mechanical Engineering student at the University of Toronto. I build end-to-end electromechanical systems.

I believe in first-principles empiricism: derive constraints from physics, then expand knowns through controlled iteration. This helps me design and solve problems in a grounded and quick fashion.


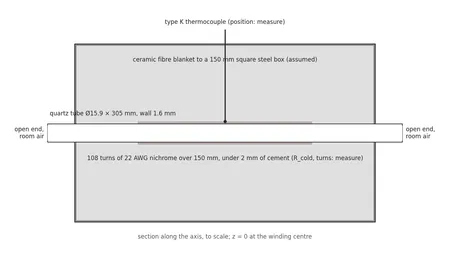
Tube furnace

Modelled the chapter's existing furnace before measuring it: a ±5 °C flat zone of 26 mm (17 to 41 over the unmeasured inputs), 48 s to the quartz limit if the relay fails closed, and an element at 1153 °C at full power.

in progress · last entry

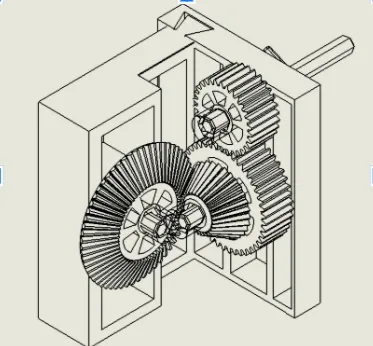
3:1 printed gearbox

An optimizer-sized 3D-printed 3:1 gearbox, exact 3:1 with gears at most 30 mm across. A hand check later found its safety factors wrong.

built and tested

Camera robot (design study)

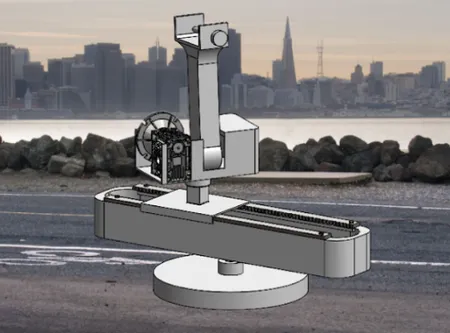
Requirements and CAD for a 4-DOF camera robot: 17 verifiable specs, $1,435 BOM, 28% under budget. Not built.

design study

Compliant finger joint

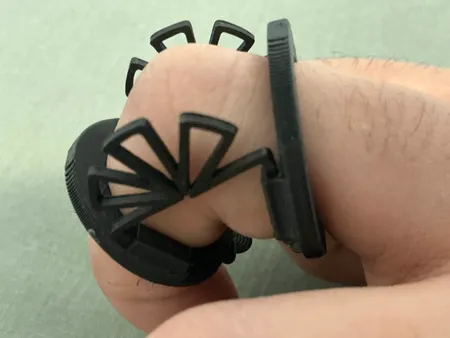
A printed compliant joint for a rehab glove: elastic to 90° in nonlinear FEA, restoring torque above the 0.012–0.015 N·m friction floor.

built and tested

Tremor stabilizer glove

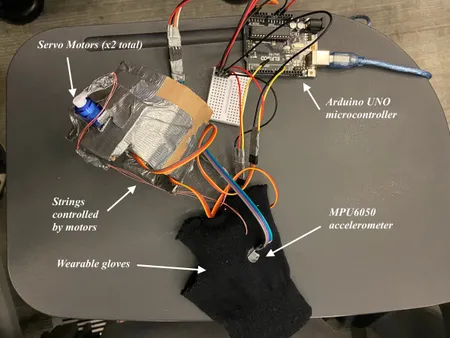
A tremor-damping glove built in 48 h: Best Prototype and Top 3 at NeuroHack 2025. Tremor reduction not quantified.

built and tested